9. Homotopy
We would like to make the following definition:
Definition 9.1 (Bogus).
Let and be topological spaces, and let be two continuous maps from to , or in other words, two elements of . We say that and are homotopic if there is a path from to , so that and lie in the same path component of . This is an equivalence relation, by Proposition 5.9; the equivalence classes are called homotopy classes of maps. We define , so is the set of all homotopy classes of maps from to .
This is bogus, because we have not introduced a topology on the set , so it is not meaningful to talk about continuous paths. As we mentioned in Remark 7.28, it is possible to introduce an appropriate topology on , but this involves many subtle technicalities. We therefore reformulate the definition in a different way.
Definition 9.2.
Let and be topological spaces, and let be two continuous maps from to . A homotopy from to is a continuous map such that and for all . We say that and are homotopic if there is a homotopy between them, and we write in this case.
Proposition 9.3.
The relation of being homotopic is an equivalence relation.
Proof.
This is closely analogous to Proposition 5.9.
-
(a)
We can define a homotopy from to by for all . This proves that , so the relation is reflexive.
-
(b)
Suppose that , so we can choose a homotopy from to . The function then gives a homotopy from to , proving that . Thus, the relation is symmetric.
-
(c)
Now suppose that and , so we can choose a homotopy from to , and another homotopy from to . We then define by
The two clauses are consistent, because when we have
The combined map is easily seen to be continuous on when restricted to the sets and . These sets are closed (in the product topology), and their union is all of , so the full map is continuous by Proposition 3.35. It gives a homotopy from to , proving that the homotopy relation is transitive.
∎
Definition 9.4.
The equivalence class of a continuous map is called the homotopy class of . We define , so this is the set of all homotopy classes.
Example 9.5.
Consider a continuous map . Then represents a closed loop in the complex plane, which cannot pass through the origin, but which can wind around the origin. Let be the total number of times the curve winds around the origin, with anticlockwise turns counting positively, and clockwise turns counting negatively. We call this the winding number of . (We will formulate the definition more carefully at a later stage.)
It can be shown that two maps from to are homotopic iff they have the same winding number. It follows that the map induces a bijection .
Example 9.6.
Let be an arbitrary topological space, and let be a subset of , with the subspace topology. Let be continuous maps. We can then define a map by
In general, we have no right to expect that this will land in the subspace , so it will probably not provide a homotopy between and . However, in some special cases we may be able to prove that , and in that case we do get a homotopy from to , which we will call a straight line homotopy.
For the most extreme example of this, suppose that is convex (as in Example 5.11), so that for all , the line segment from to is contained wholly in . Let and be continuous maps from to , and put as before. Then lies on the line segment from to , so for all and . Thus, gives a homotopy from to , proving that in . As and were arbitrary, it follows that .
We next check that the notion of homotopy is compatible with composition.
Proposition 9.7.
Suppose we have continuous maps
Suppose that is homotopic to , and that is homotopic to . Then is homotopic to .
Proof.
We are assuming that is homotopic to , which means that there is a homotopy with and for all . We are also assuming that is homotopic to , which means that there is a homotopy with and for all . We can therefore define by
This satisfies and . Thus, gives the required homotopy, provided that we can check that it is continuous. The tidiest proof of continuity is as follows: we let be the projection, and note that can be written as the composite
Here is continuous by Lemma 7.10, so is continuous by Proposition 7.11, so is continuous by Proposition 3.24. ∎
Corollary 9.8.
For and , there is a well-defined composite , given by for any choice of maps with and .
Proof.
Immediate from the proposition. ∎
Definition 9.9.
We can now define a new category , called the homotopy category. The objects are topological spaces (just as for the category ), but the morphisms are now homotopy classes of maps, so
The composition rule is given by Corollary 9.8. The identity morphism in for an object is just the homotopy class corresponding to the identity function.
Definition 9.10.
A continuous map is a homotopy equivalence if the corresponding homotopy class is an isomorphism in the homotopy category. Explicitly, this means that there must exist a continuous map such that and . Any such map is called a homotopy inverse for . If there exists a homotopy equivalence from to , we will say that and are homotopy equivalent. We will sometimes use the notation to indicate this.
Lemma 9.11.
Every homeomorphism is a homotopy equivalence.
Proof.
Let be a homeomorphism, with inverse . This means that and . As is equal to , it is certainly homotopic to . As is equal to , it is certainly homotopic to . Thus, is also a homotopy inverse for , so is a homotopy equivalence. ∎
A basic example is as follows:
Proposition 9.12.
For , the sphere is homotopy equivalent to the space .
Proof.
Recall that . We define to be the inclusion function, so we just have . We define by . (It is important here that is the space of nonzero vectors in , so and it is valid to divide by .) Note that for we have so , so . As is equal to , it is certainly homotopic to . In the opposite direction, however, the composite is not equal to the identity. Nonetheless, we can define by
Here is always strictly positive (for ), so can never be zero, so we can regard as a map . Now and , so is a homotopy from to . This proves that is a homotopy inverse for , so that is a homotopy equivalence.
∎
Definition 9.13.
Let be a topological space, and let be a point in . A contraction of to is a continuous map such that for all , and for all . We say that is contractible if it has a contraction (to some point ).
Example 9.14.
Let be a convex space, and let be a point in . We can then define a linear contraction of to by , so is contractible. In particular, the spaces , and are all contractible.
Example 9.15.
The sphere is not contractible, as you will probably agree if you try to imagine a contraction. However, at the moment we do not have any way of proving this.
Definition 9.16.
We write for the set (or any other set with precisely one element). We regard this as a topological space using the discrete topology (which is in fact the only possible topology in this case).
Proposition 9.17.
A space is contractible iff it is homotopy equivalent to .
Proof.
Suppose that is homotopy equivalent to . This means that we have maps and , and a homotopy from to , and a homotopy from to . As there is no choice about : we must have for all . Similarly, there is no choice about : we must have for all . However, there is some choice about and . Put . We then have for all . Moreover, is a homotopy from to , so we have and for all . Thus, is a contraction t , showing that is contractible.
Conversely, suppose that we start from the assumption that is contractible. All the above steps can be reversed in a straightforward way to prove that is homotopy equivalent to . ∎
Remark 9.18.
The map is the most basic example of a homotopy equivalence that is not a homeomorphism.
Proposition 9.19.
The relation of being homotopy equivalent is an equivalence relation.
Proof.
The identity function from to itself is clearly a homotopy equivalence, so the relation is reflexive. Suppose that is homotopy equivalent to , so we can choose a homotopy equivalence and a homotopy inverse , so and are homotopic to the respective identity maps. This means that is a homotopy equivalence with homotopy inverse , so is homotopy equivalent to . This proves that our relation is symmetric. Finally, suppose that is homotopy equivalent to and is homotopy equivalent to . Let and be homotopy inverses for and , so and and . Using Proposition 9.7, we deduce that
This proves that is a homotopy equivalence, with homotopy inverse . This in turn shows that our relation is transitive, as required. ∎
Proposition 9.20.
Suppose that is homotopy equivalent to and is homotopy equivalent to . Then is homotopy equivalent to .
Proof.
For we let be a homotopy equivalence, with homotopy inverse . This means that we have homotopies from to , and homotopies from to . Now make the following definitions:
We find that gives a homotopy from to the identity, and gives a homotopy from to the identity, so we have a homotopy equivalence between and , as required. ∎
Example 9.21.
The solid torus, the Möbius band, and are all homotopy equivalent to . To explain this in more detail, let be the vertical disc in the plane of radius centred at . The “solid torus” is the space obtained by revolving around the -axis; this is easily seen to be homeomorphic to . Now is convex, so it is homotopy equivalent to . It follows that is homotopy equivalent to .
Next, for , let be the vertical plane through the -axis in that has angle with the -plane. Let be the intersection of with the solid torus, which is a vertical disc of radius centred at . Let be the diameter of that makes an angle of to the vertical, and let be the union of all the sets . This is a version of the Möbius band. It is homeomorphic to the space
Define and and by
Then and is a homotopy from to , so is a homotopy inverse for , so is homotopy equivalent to as claimed.
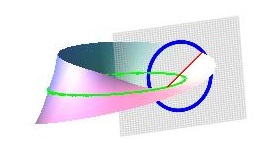 |
Finally, Proposition 9.12 tells us that is homotopy equivalent to , and can be identified with , so is also homotopy equivalent to .
Definition 9.22.
Let and be topological spaces. We say that is a homotopy retract of if there exist continuous maps such that is homotopic to . (We make no assumption about .) Any pair with this property will be called a homotopy retraction pair for .
Example 9.23.
Put
Note that is two-dimensional whereas is one-dimensional so there is no injective continuous map from to , so is not an actual retract of . However, it is a homotopy retract of . To see this, define maps by
The composite is just . The straight line joining to does not pass through the origin, so is homotopic to the identity as required. (The map is not homotopic to the identity, so we do not have a homotopy equivalence, but that is not important.)
Proposition 9.24.
Suppose that is a homotopy retract of and that is contractible. Then is also contractible.
Proof.
By hypothesis, we have continuous maps
such that , and are homotopic to the respective identity maps. Now put and . We then have . Also, is a map from to , and the only map from to is the identity, so . Thus, and give a homotopy equivalence from to , proving that is contractible. ∎
Proposition 9.25.
Suppose we have two continuous maps , giving maps as in Proposition 5.20. If is homotopic to , then .
Proof.
Let be a homotopy between and , so and for all . For any we have and . We need to prove that these are the same. Equivalently, we need to find a path from to in . We can just take . ∎