11. Homology of the punctured plane
Later we will prove that for all we have
For this we will need the Mayer-Vietoris sequence, which is a very important and useful tool, but it will take some work to set that up. In this section, we outline a different approach which is more direct and elementary but which works only for . We will identify with and write , so our main task will be to prove that .
Definition 11.1.
Let be a nonzero complex number. This can be expressed as for a unique pair or real numbers with and . We put , and call this the principal logarithm of .
Note that and for all , but is not continuous (because for small we have but ). This cannot be fixed by adjusting the definitions: there is no continuous map with for all . To work around this we make the following definition:
Definition 11.2.
For any we put
Any element of will be called a logarithm of . More generally, suppose we have a topological space and a continuous map . By a continuous logarithm of we mean a continuous map with , or equivalently for all .
Note that the cosets and are the same, and that is close to this coset for all small , independent of whether is positive or negative. Thus, depends continuously on even though does not.
Given a continuous map , we could attempt to define a continuous logarithm of by . This works provided that the image does not touch the negative real axis where is discontinuous. If does touch the negative real axis then it may be possible to find a continuous logarithm by a different method, but in some cases, no continuous logarithm exists.
Lemma 11.3.
Let be continuous, and suppose that . Then there is a unique continuous logarithm with .
We will prove this properly later when we come to discuss covering maps.
Sketch proof.
If we choose sufficently large, then when the points will be close to in and so will be far from the negative real axis where is discontinuous. We can thus define
This is a continuous function of . When we see that all the terms in the sum are , so . In general we have
and most of the terms in the product cancel out leaving only . ∎
Corollary 11.4.
Let be convex, and suppose that . Let be continuous, and suppose that . Then there is a unique continuous logarithm with . (In particular, this applies when for some .)
Sketch proof.
For we can define by . By the lemma, there is a unique continuous logarithm with . We define , so . We have for all so must be the constant path at so . With some work one can check that is continuous. ∎
Definition 11.5.
Given any path we define
where is any continuous logarithm of . (This is well-defined, because any two continuous logarithms differ by a constant of the form , and the constant cancels out when we calculate .) We then extend this linearly to get a homomorphism , given by
Example 11.6.
The standard loop of winding number is given by . The obvious continuous logarithm is , and using this we get .
Lemma 11.7.
For we have . Thus, we have .
Proof.
For we put , so . By Corollary 11.4, we can choose a continuous logarithm for . We then note that the map is a continuous logarithm for for , so . This gives
However, we have
so the above expression becomes
so as claimed. More generally, if then for some integers and maps , and this gives
as before. Thus, if then for some giving as claimed. ∎
Definition 11.8.
We now define homomorphisms and by and
(Here we regard and as groups under addition and as a group under multiplication, so to say that and are homomorphisms means that and ; it is easy to see that both of these identities are valid.)
Lemma 11.9.
The following square commutes (or in other words, for all ).
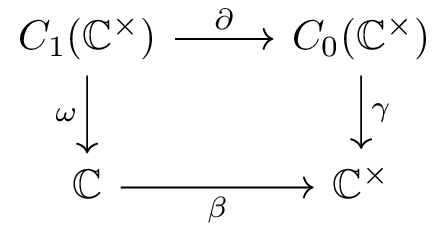
Proof.
In general will be a -linear combination of paths in , but all the maps are homomorphisms, so it will be enough to consider the case where is just a single path. We then have and so . Now choose a continuous logarithm for . By definition we have , so
∎
Corollary 11.10.
We have and , so induces a homomorphism given by .
Proof.
Theorem 11.11.
The homomorphism is an isomorphism.
Proof.
We have already remarked that for all ; this shows that is surjective. Now suppose we have with . By Proposition 10.29, we can find a loop based at with . By Lemma 11.3, there is a unique continuous logarithm with . We then have . However, we also know that , so we must have as well. We now define by
We leave it to the reader to check that is continuous even at . (A full proof of a more general fact will be given later.) We then define . It is easy to see that is a filling in for , and thus that is a filling in for , so in by Lemma 10.31, or in other words . This proves that is also injective, and so is an isomorphism as claimed. ∎