7. Constructing new spaces
We next need to discuss several ways of constructing new topological spaces from spaces that we already know about.
Definition 7.1.
Let and be disjoint sets, and put . Suppose we are given topologies on and , which we use to regard them as topological spaces. We then declare that a subset is open iff is open in the given topology on , and is open in the given topology on . This is easily seen to give a topology on , which we call the coproduct topology.
Remark 7.2.
We now have a topology on , and is a subset of , so we can use Definition 3.25 to define a subspace topology on . It is easy to see that this is just the the same as the original topology on . Similarly, if we regard as a subspace of , then the subspace topology is just the same as the original topology. In particular, the inclusion maps are continuous.
The category-theoretic viewpoint encourages us to ask the following kind of question: whenever we construct a new object in a category , we should try to prove theorems describing the set of morphisms into , and/or the set of morphisms out of , for an arbitrary object .
Proposition 7.3.
Let , and be as above, and let be another topological space. To describe a function , it is enough to specify the restricted functions and . Moreover, the combined map is continuous (with respect to the coproduct topology) iff and are continuous (with respect to the originally given topologies on and ). Thus, we have a bijection between and .
Proof.
Consider an open set . We then find that and . Thus, is open in iff is open in and is open in . Thus, is continuous iff this condition holds for all iff and are continuous. Thus, to give a continuous map is the same as to give a pair of continuous maps and , or in other words a pair . ∎
Remark 7.4.
There is a general notion of coproduct objects in category theory. The above proposition can be interpreted as saying that (equipped with the coproduct topology) is the coproduct of and in this general categorical sense.
Proposition 7.5.
Let , , and be as above, and consider a function . Then is continuous iff
-
(a)
The sets and are open in .
-
(b)
The restricted map is continuous with respect to the subspace topology on .
-
(c)
The restricted map is continuous with respect to the subspace topology on .
Proof.
Left as an exercise. ∎
Definition 7.6.
Let and be topological spaces, and consider the product
For a point , a box around means a set of the form , where and and is open in and is open in . We declare that a set is open iff for all , there is a box around that is contained in .
Example 7.7.
The picture shows the case where and . We have indicated a subset , two points , a box around contained in , and a box around contained in .
Lemma 7.8.
Suppose that is an open subset of and is an open subset of . Then is open in .
Proof.
Consider a point , so and . We need to show that there is a box around such that . We can just take . ∎
Proposition 7.9.
Definition 7.6 specifies a topology on (which we call the product topology).
Proof.
First suppose we have a family of open sets ; we must show that the union is open. Consider a point . By the definition of the union, this means that for some . As is open, we can choose a box around such that . Now , so we also have . Thus, every point in has a box that is contained in , so is open as required.
Now suppose we have a finite list of open sets ; we must show that the intersection is open. Consider a point . By the definition of the intersection, we have for all . As is open, we can choose a box around such that . Put and and . For all we have and , so and . By the topology axioms for , the set is open in . By the topology axioms for , the set is open in . It follows that is a box around that is contained in , as required.
We also see that is open (because there are no points to check, so the definition is vacuously satisfied). Also, the set itself is a box around each of its points, so is open. This completes the proof that we have defined a topology. ∎
Again, the categorical viewpoint encourages us to try to analyse the continuous maps to or from . For maps out of there is no simple answer, but maps into are quite easy.
Lemma 7.10.
The projection maps (given by and ) are continuous.
Proof.
Let be an open set. We must show that is open in , but is just the same as , which is open by Lemma 7.8. The proof for is essentially the same. ∎
Now consider a topological space and a function . This must have the form for some functions and . We denote this by . We can also express the component functions and as and .
Proposition 7.11.
The combined map is continuous (with respect to the product topology) iff the component functions and are continuous. Thus, there is a bijection between the sets and , in which the element corresponds to the pair .
Proof.
Suppose instead that we start from the assumption that and are both continuous. Consider an open set ; we must show that is open. The simplest case is where is a box, say , where is open in and is open in . We then have
This shows that , and this set is open because and are continuous.
Now return to the general case of an arbitrary open set , which need not be a box. For each point , we have . As is open with respect to the product topology, there is a box with . We put , so . The previous paragraph shows that is open. Moreover, we find that is the union of all the sets . The union of any family of open sets is open, so is open as required. ∎
Remark 7.12.
There is a general notion of product objects in category theory. The above proposition can be interpreted as saying that (equipped with the product topology) is the product of and in this general categorical sense.
We now turn our attention to quotient constructions. We recall the basic definitions.
Definition 7.13.
Let be a set, and let be a relation on (so for each pair we have a statement , which may or may not be satisfied).
-
(a)
We say that the relation is reflexive if for all .
-
(b)
We say that the relation is symmetric if whenever , we also have .
-
(c)
We say that the relation is transitive if whenever and , we also have .
-
(d)
We say that the relation is an equivalence relation if it is reflexive, symmetric and transitive.
-
(e)
If we have an equivalence relation, we write , and call this the equivalence class of . We note that
-
(i)
The relation holds iff
-
(ii)
For each we have
-
(iii)
If , then the subsets are disjoint, i.e. .
Although the equivalence classes are defined as subsets of , we will often deemphasise that fact, and just treat them as abstract symbols satisfying property (i).
-
(i)
-
(f)
We write for the set of all equivalence classes, so . We define a map by , so is surjective and iff . Informally, we say that is obtained from by identifying points and whenever . We may also say “gluing together” instead of “identifying”.
Definition 7.14.
Suppose we have sets and , and an equivalence relation on . We say that a function is -saturated if whenever in , we have in .
Proposition 7.15.
-
(a)
The quotient map is -saturated.
-
(b)
For any function , the composite is -saturated.
-
(c)
For any -saturated function , there is a well-defined function given by . This is the unique such that . (We call it the function induced by .)
Proof.
Claim (a) follows from Definition 7.13(e)(i), and claim (b) follows immediately from (a). For claim (c), we need to define for each equivalence class . To do this, we pick any with , and take . There could in principle be a problem with this. If we choose a different such that is also equal to , then we should also have , and this would be inconsistent if was different from . However, in this situation we have so so by the -saturation condition. Thus, no inconsistency can arise, and we have a well-defined function as claimed. The equation is just another way of writing the condition , so it is clear that there is a unique function with this property. ∎
Corollary 7.16.
There is a one-to-one correspondence between functions , and -saturated functions . ∎
Definition 7.17.
Now suppose we have a topological space , together with an equivalence relation on . We declare that a subset is open iff the preimage is open in .
Proposition 7.18.
The above definition gives a topology on (which we call the quotient topology). Moreover, the quotient map is continuous with respect to this topology.
Proof.
Suppose we have a family of subsets that are open with respect to the quotient topology. We must show that the union is also open. By the definition of the quotient topology, we see that the sets are open in , and we must show that is also open in . As the sets are all open, the set is also open, by the topology axioms for . Moreover, we have by Lemma 3.11(a), so is open as required. The proof for finite intersections is similar. We also have , and is open in by the topology axioms for , so is open in by our definition of open sets in . Similarly, we have , which is open in , so is open in . This completes the proof that we have a topology on .
We also want to prove that is continuous. In other words, for every set that is open with respect to the quotient topology, we must show that is open in . But this is true by the very definition of the quotient topology. ∎
Proposition 7.19.
Let and be as above, and let be a function from to another topological space . Then is continuous (with respect to the quotient topology on ) iff the composite is continuous.
Proof.
We have seen that is continuous and that composites of continuous functions are continuous. Thus, if is continuous, then the composite is also continuous as claimed.
Suppose instead that we start from the assumption that is continuous; we must show that is continuous. Let be open; we must show that the preimage is open in . By the definition of the quotient topology, it is equivalent to prove that the set is open in . However, we have , and this is open as required because is assumed to be continuous. ∎
Corollary 7.20.
Let be an -saturated function. Then the induced function is continuous iff is continuous. Thus, we have a one-to-one correspondence between continuous functions , and -saturated continuous functions .
Proof.
As , this is just a restatement of the proposition. ∎
Remark 7.21.
This corollary could be put in a common framework with the first isomorphism theorem for groups, if we took the time to develop the relevant categorical notion of coequalisers.
Example 7.22.
We can define an equivalence relation on by iff . The real projective space is defined to be the quotient space . Similarly, we can regard as the unit sphere in the space . We can then define another equivalence relation on by declaring that iff for some . The complex projective space is defined to be .
Example 7.23.
We will prove that the real projective space is homeomorphic to . Recall that , where iff . We will identify with by the usual Argand corrspondence . We define by . This clearly satisfies , so it is -saturated and induces a map with for all . Now suppose we have a point . Then the set is an -equivalence class, or in other words a point of the space , so we have a map . It is easy to see that this is inverse to , so is a continuous bijection. We just need to check that is also continuous. Suppose that is open, and contains for some point . This means that , and is open in by the definition of the quotient topology, so there is some such that whenever . It follows that whenever . From this we can deduce that is open as required.
Example 7.24.
Put
This consists of two closed discs, as shown on the left below.
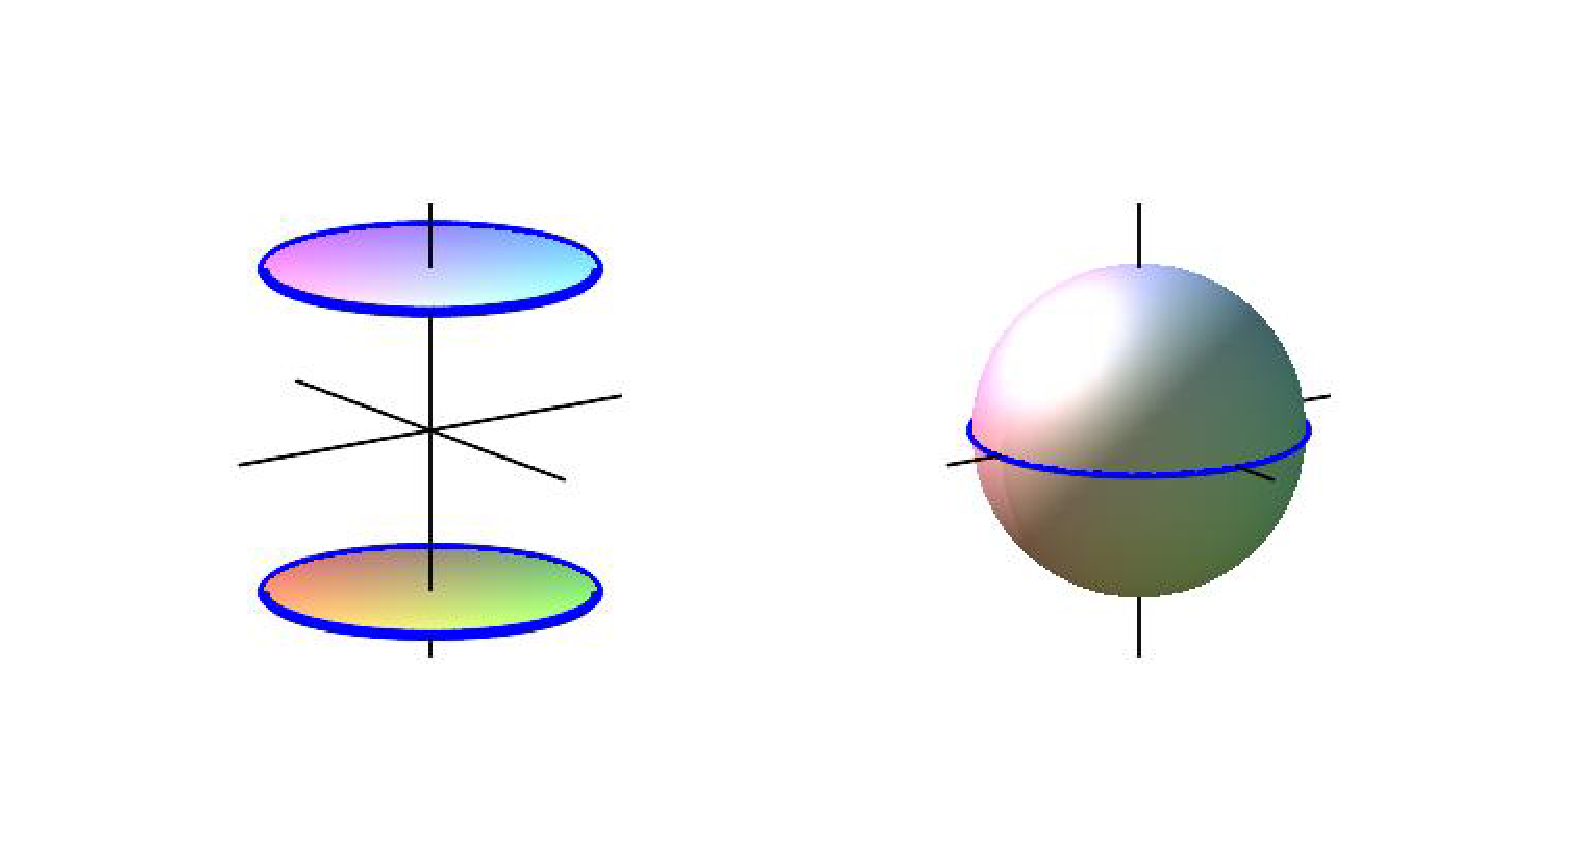
If we glue together the boundary circles of the two discs, we get a sphere, as shown on the right. We can make this more formal and rigorous as follows. We introduce an equivalence relation on by declaring that if , or if with . We define by , as illustrated below.
This is clearly continuous. Also, if then we have , so is -saturated. We therefore have an induced map , and Corollary 7.20 tells us that this is continuous. It is not hard to check that is a bijection. However, we saw in Example 4.10 that not every continuous bijection has a continuous inverse, so we cannot immediately conclude that is a homeomorphism. It would be possible but fiddly to prove this directly. However, we will see an efficient general method for this in Section 8, so we will defer further comment until then.
Example 7.25.
From the Knots and Surfaces course you should remember pictures like this:
We take a filled octagon , with edges marked , , or as shown. There are two edges marked , and we glue them together in the direction indicated by the arrows. We do the same for the labels , and . To make this more formal and rigorous, we introduce a relation as follows: we declare that if
-
•
; or
-
•
for some we have and ; or
-
•
for some we have and ; or
-
•
for some we have and ; or
-
•
for some we have and ; or
-
•
for some we have and .
One can check that this is an equivalence relation, so we can form the quotient space . One can then show that is homeomorphic to the usual kind of double torus embedded in .
Example 7.26.
Consider the spaces and
(so is a version of the torus). We introduce an equivalence relation on by declaring that iff . We then define by
It is easy to see that this is continuous and -saturated, so it induces a continuous map . It is also easy to see that is a bijection. It is again true that is also continuous, so that is a homeomorphism, but we will again defer the proof.
Example 7.27.
Here is a more exotic example. We start with the space , and we declare that if either , or with . In other words, we start with the two lines where and and then we glue them together, except that we leave the points and unglued. The quotient space is called the line with doubled origin. It has various unpleasant properties, and we mostly choose not to study spaces with those properties; that is the point of the Hausdorff condition to be introduced in Section 8.
Remark 7.28.
There is one more construction that we would like to treat, but will not. Let be any metric space. From the Metric Spaces course, you should remember that the set (of continuous functions from to ) has a metric of its own, which is useful for many purposes. It would also be useful to define a similar topology on for arbitrary topological spaces and . This seems natural, because it is easy to imagine what we mean by saying that two functions are close to each other, which is the basic idea that we need when defining a topology. Unfortunately this leads to a host of technical difficulties and subtle distinctions. A huge detour is necessary before one can set up a clear and coherent theory. Thus, we will motivate various constructions using the idea of treating as a topological space, but we will not use this idea in our formal definitions.
Proposition 7.29.
Let and be disjoint spaces, and take , with the coproduct topology. Then is the disjoint union of and .
Proof.
We can define by for , and for . This is clearly continuous when restricted to or , so it is continuous on all of by Proposition 7.3. If is a continuous path, then is also continuous, so it clearly must be constant. (Formally, the proof uses the Intermediate Value Theorem.) Thus, the path lies wholly in or wholly in . Given this, the claim is clear from the definitions. ∎
Proposition 7.30.
Let and be topological spaces. Then can be identified with . More precisely, let be the projections, which give rise to maps as in Proposition 5.20. We can therefore define a map
by , and this is a bijection.
Proof.
We would like to define as follows: an element of can be written as for some and , and these give a point and a path component , and we want to define . We must check that this is well-defined. Suppose that in . This means that in , so there is a continuous path in . It also means that in , so there is a continuous path in . We define by (which is continuous by Proposition 7.11). This gives a path in , proving that , as required. Thus, our definition of is valid. We can describe in similar terms by . (We do not need to check separately that this is well-defined, because that was done already in Proposition 5.20 which we used to define and .) It is now clear that and are inverse to each other, so is a bijection as claimed. ∎